Dive stages
- Stage 1Hot tub, 80 cm – sealing and control
- Stage 2Local lake, 5 m – first open-water dive
- Stage 3Kaatiala, 30 m – depth test
- GoalOperation Pakasaivo – a dark meromictic lake in Lapland, bottom at about 60 m
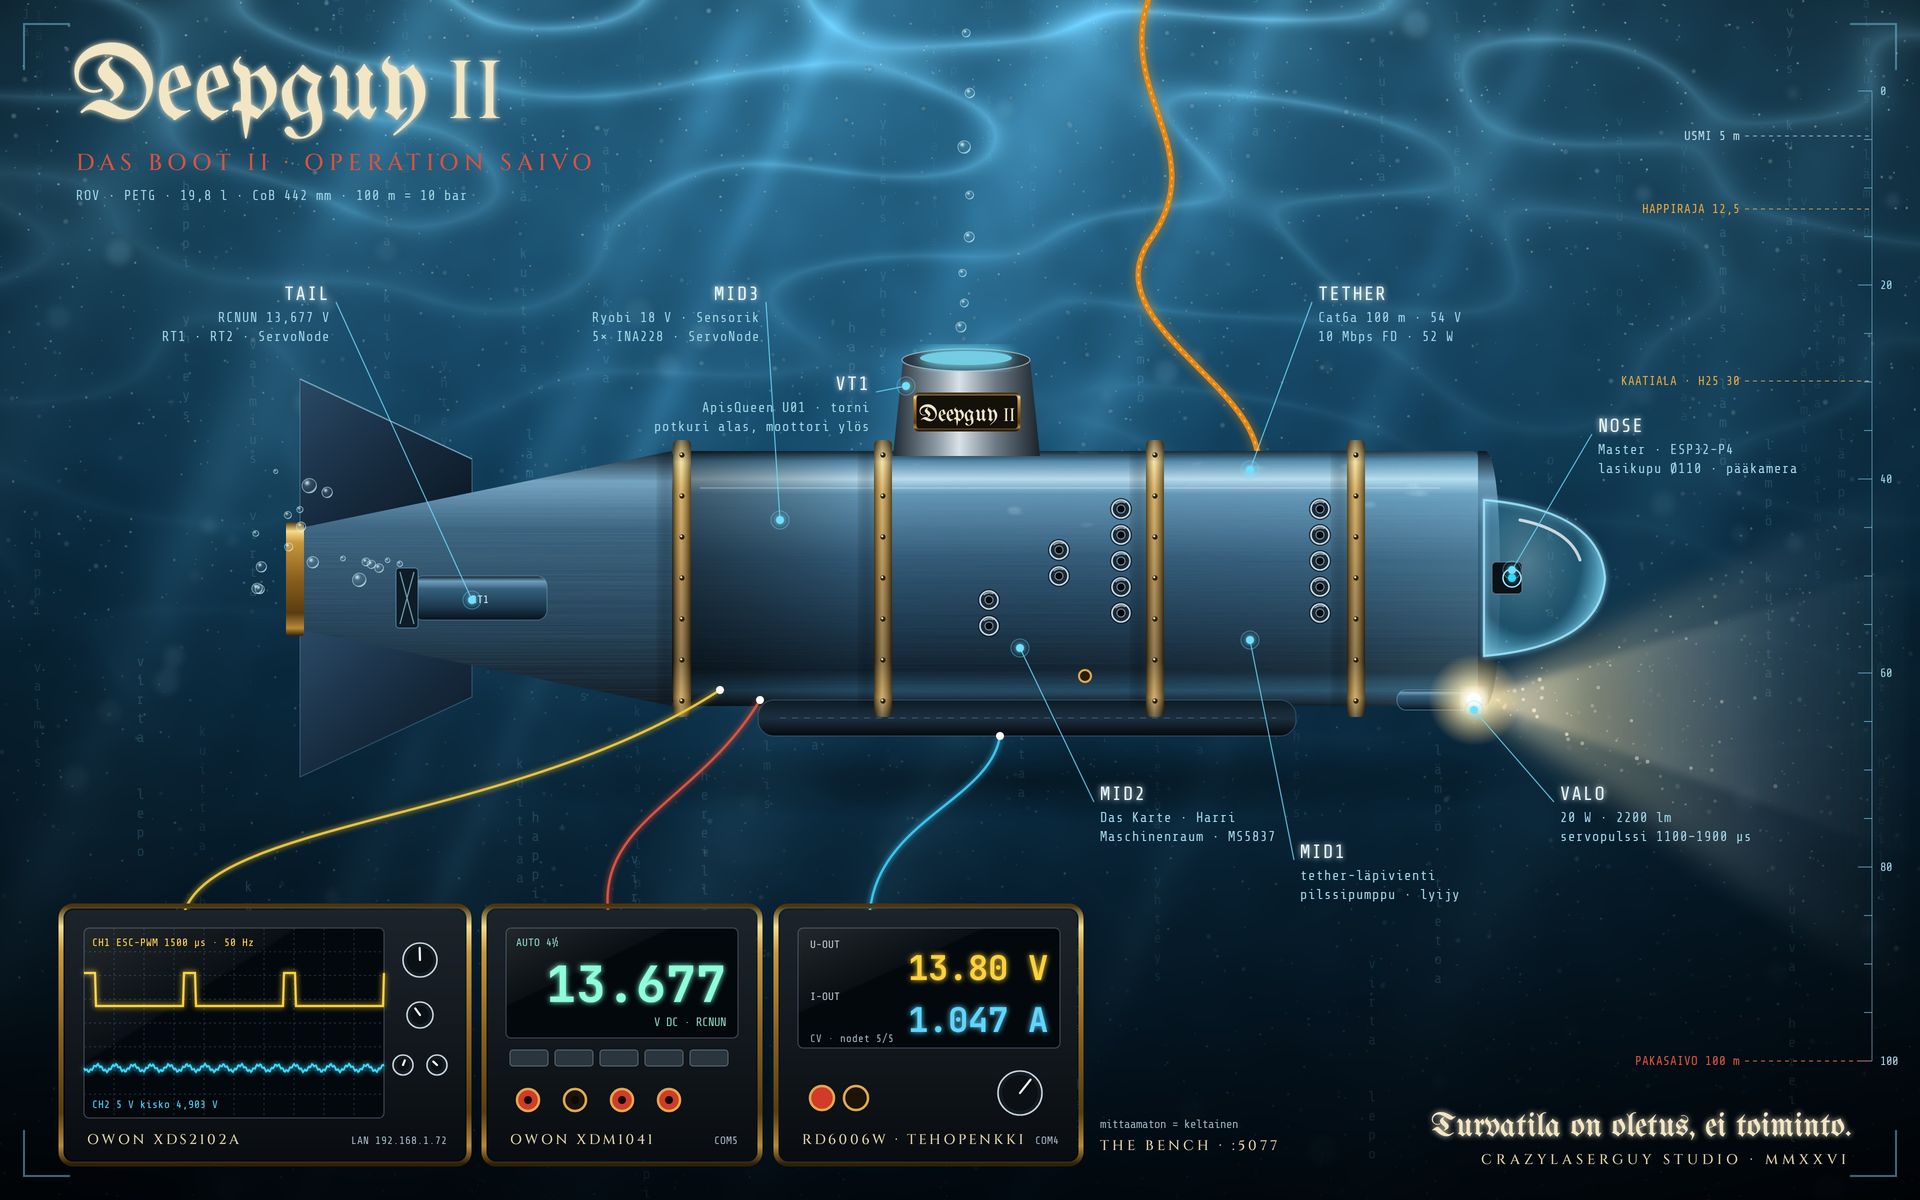
Home-built filming robot · ROV
DeepGuy is a tethered ROV – an underwater filming robot whose nose camera streams straight to the pilot's VR headset. Designed and 3D-printed in a home studio. The journey runs from a hot tub to the 60-metre bottom of Lake Pakasaivo – narrated by Harri, who dives in calm English and panics in German.
An ROV assembled from seven printed sections: the nose with its glass dome, five mid sections and the tail. The whole sub is fully assembled before every dive.
An ESP32-P4 main board and nine ESP32 nodes for cameras, sensors, mapping, power and thrusters.
Data and power in one 50-metre cable to the surface, where the command center and a wireless hand controller sit. A 100-metre tether is coming for deeper dives.
A 5-megapixel 160° wide-angle camera in the nose, plus auxiliary cameras. Video and HUD (compass, horizon, depth, map) in a Meta Quest headset and the command center.
PETG hull Ø 175 mm with O-ring flanges. Three thrusters, a 20 W dive light, sonar, depth sensor, leak alarm and bilge pump.
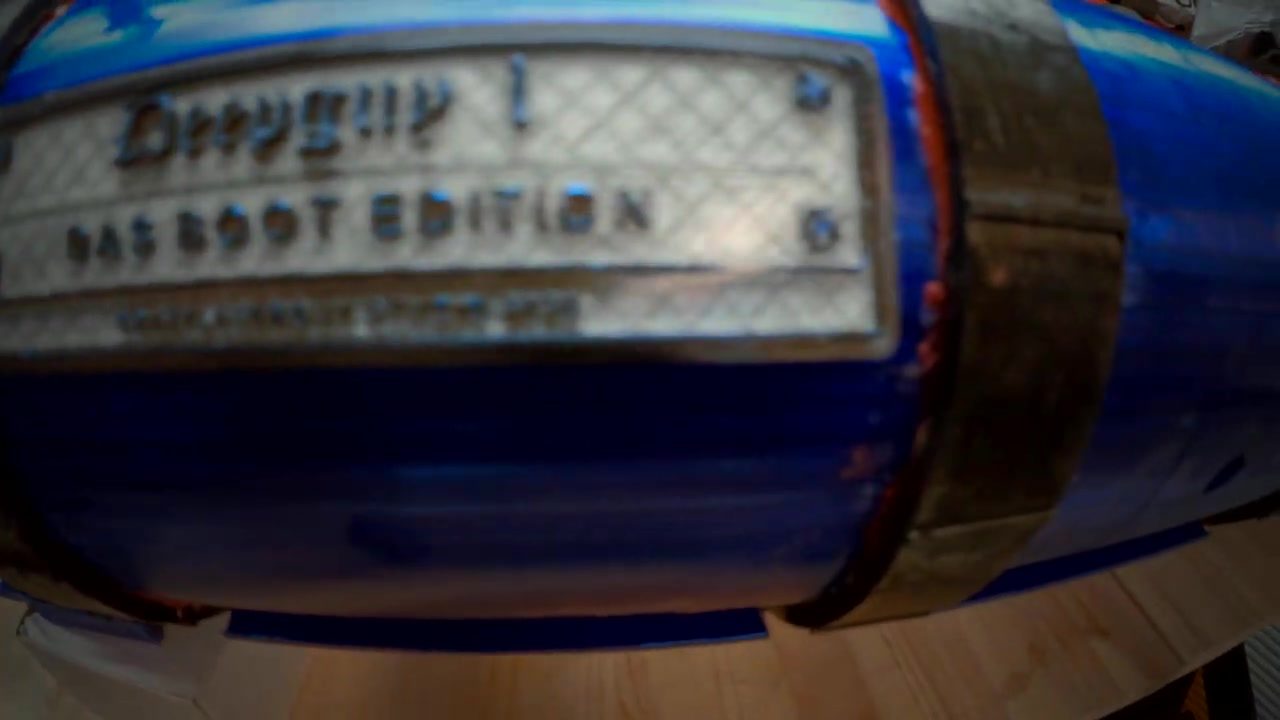
It all started with a question: can you print an underwater robot from PETG plastic? DG1 was the first printed sub: external waterproof thrusters, O-ring joints, lead ballast and a tether to the surface. A sink test in the hot tub showed what the next sub had to do differently – and that became DG2.
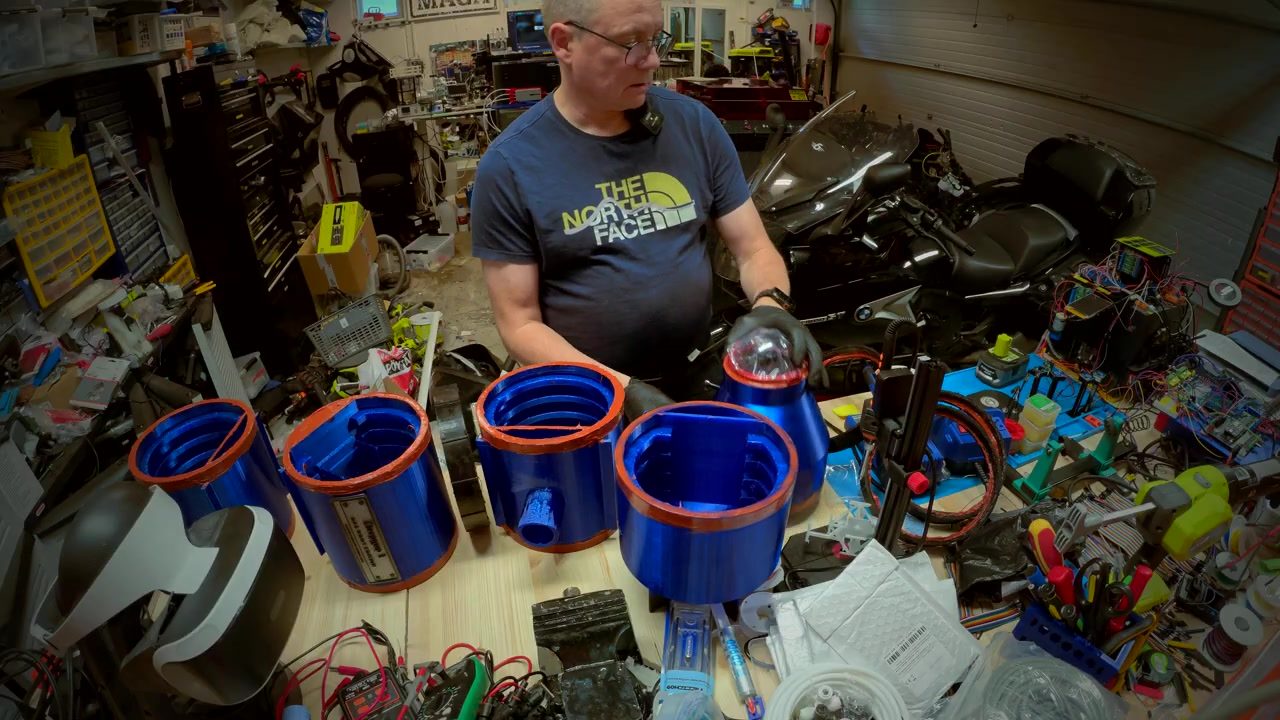
The build and the dives, episode by episode, on @Crazylaserguy. A new episode every other week.
 COMING SOONCOMING SOONCOMING SOONCOMING SOONCOMING SOONCOMING SOONCOMING SOONCOMING SOONCOMING SOONCOMING SOON